COAST: Safe Flight Corridor Planner for Fast and Robust Snap-Minimized Trajectories
BYU MAGICC Lab · Advisor: Dr. Randal W. Beard
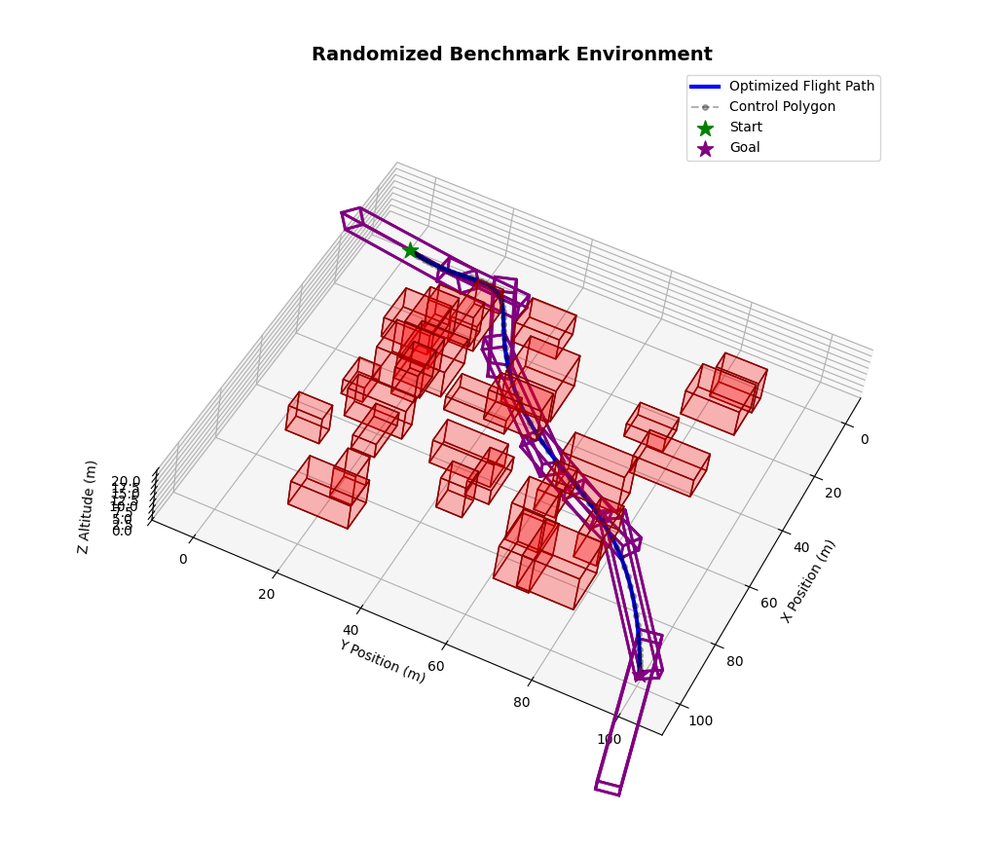
An online trajectory planner for multirotor and fixed-wing UAVs that combines the mathematical guarantees of safe flight corridors with the speed of B-spline optimization.
- C++ planner using KD-tree spatial projections and B-spline kinodynamic bounding, with sub-10 ms computation times
- Simulated LiDAR point clouds feed an OSQP quadratic program in RViz, keeping trajectories dynamically feasible and inside continuous-space safe flight corridors
- 2nd place nationally, SHPE 2026 undergraduate research poster competition (poster · BYU ECE news ↗)